Running PushNav headless on a Raspberry Pi
PushNav runs headless on a Raspberry Pi 3A+, 4 or 5 as the pushnav-headless
package. There is no window: PushNav runs in the background as a system
service, and you control it from a phone or laptop browser at
http://<pi-address>:8765. The laptop builds (macOS .dmg, Windows
installer, Linux AppImage) are separate and unchanged.
Where to get it
The Pi package comes with the PushNav releases from v0.3.0-beta7 on.
On the releases page,
pick the newest release that lists pushnav-headless_<version>_arm64.deb
(it may be marked Pre-release). It sits next to user-data, which
method B below uses. If no release lists it yet,
build the package yourself.
Beta
The Raspberry Pi package is new. It has been tested on a Raspberry Pi 5 and a Raspberry Pi 3A+ running Raspberry Pi OS (trixie), including the ready-made SD card on the 3A+, and in clean Debian bookworm and trixie installs. The Pi 4 hasn't been tested yet but is expected to work, since it sits between the two. Please report problems.
Which way to install?
There are two ways to set up the Pi. Both install the same package, and everything after the install (status light, debug mode, updates) works the same.
| A. Install with apt | B. Ready-made PushNav SD card | |
|---|---|---|
| Best for | People used to setting up a Pi, or a Pi that also does other things | A dedicated PushNav box, with no command line needed |
| Network | Your existing Wi-Fi or Ethernet | The Pi's own Wi-Fi hotspot, PushNav-XXXX (no internet needed) |
| Open PushNav at | http://<pi-address>:8765 |
http://192.168.77.1:8765 |
| Setup | Flash the card the usual way, SSH in, apt install the package |
Flash the card, copy two files onto it, boot |
| Raspberry Pi OS | 64-bit, bookworm or trixie | 64-bit Lite, trixie only |
What you need
- A Raspberry Pi 3A+, 4 or 5 with 64-bit Raspberry Pi OS. The Lite (no desktop) edition is enough. In Raspberry Pi Imager, pick a 64-bit OS; the package doesn't install on 32-bit. PushNav uses about 150 MB of memory, so even the 3A+'s 512 MB is enough.
- Speed: a Pi 5 solves the sample frames in under a tenth of a second each. A Pi 3A+ manages about 2 solves per second, which is slower but still fine for push-to.
- A supported camera. The Waveshare, Arducam and DECXIN OV9281 USB modules are recognised automatically.
- A phone, tablet or laptop to open PushNav in a browser.
- Optionally, for a Pi 3A+: the 3D-printed Pi 3A+ mount and box, which carries the Pi under the camera on the telescope's finder shoe.
A. Install with apt
For a Pi you set up yourself, on your own Wi-Fi or Ethernet.
- Set up the Pi as usual with 64-bit Raspberry Pi OS (bookworm or trixie), networking and SSH, for example with Raspberry Pi Imager's OS customisation.
- On the releases page,
download
pushnav-headless_<version>_arm64.debonto the Pi. For example, copy its link and runwget <link>on the Pi. -
Install it:
sudo apt install ./pushnav-headless_*_arm64.debapt may print a notice that the download "is performed unsandboxed as root". That's normal for a local file and safe to ignore.
-
The install starts PushNav straight away, and it starts again on every boot. The last lines of the install show the address to open:
PushNav headless is installed. Open on your phone (same Wi-Fi): http://192.168.0.111:8765 -
Open that address on your phone. You can plug the camera in before or after this; PushNav picks it up within about 10 seconds, and again if it is unplugged and plugged back in.
The package includes everything it needs, including its own Python, under
/usr/lib/pushnav-headless. It doesn't touch the Pi's system Python.
B. Ready-made PushNav SD card
Turns a fresh SD card into a dedicated PushNav box with its own Wi-Fi hotspot, so it works anywhere, with no router and no internet. You copy two files onto the card after flashing it, and the Pi sets itself up on the first boot.
Use Raspberry Pi OS Lite: the box has no screen, so a desktop would only take memory away from PushNav (the 3A+ has just 512 MB) and slow the boot. Lite is also what this setup was tested with.
- Download two files from the same release on the
releases page:
pushnav-headless_<version>_arm64.debanduser-data. -
Edit
user-datain a plain-text editor. Lines markedCHANGE:- the Wi-Fi country code (
INis India; use yours, e.g.US,GB,DE,AU). The wrong country can stop the hotspot from working. - the hotspot password (
pushnav123) and the login password (pushnav), if other people may be within Wi-Fi range.
Keep the file name exactly
user-data, with no.txtor other extension. Some editors add one when saving. 3. Flash the card with Raspberry Pi Imager: choose your Pi model and Raspberry Pi OS Lite (64-bit), which is under Raspberry Pi OS (other). Skip OS customisation: when Imager offers it, choose No. 4. Copy the two files onto the card. After flashing, take the card out and put it back in. Open the partition calledbootfs(it containsconfig.txtandcmdline.txt) and copy both files to its top level, replacing theuser-datathat's already there. 5. Boot the Pi with the card and, if you have it, the camera. The first boot sets everything up and takes a few minutes. When PushNav is running, the Pi's status light blinks red slowly (no camera) or green slowly (ready). 6. Connect your phone to the Wi-Fi networkPushNav-XXXX(passwordpushnav123, unless you changed it) and openhttp://192.168.77.1:8765. Your phone may warn that the network has no internet: stay connected anyway.http://pushnav.local:8765also works on phones that support.localnames (iPhones do; many Android phones don't). - the Wi-Fi country code (
To log in to the Pi, connect to the hotspot and run ssh pi@192.168.77.1
(password pushnav, unless you changed it).
To stick these details on the box, with a QR code that opens PushNav, print a label: see Label for a ready-made Pi.
The setup in user-data runs only on the first boot. To install a
newer PushNav later, see For power users,
or flash the card again with the new files.
Connect planetarium apps
Use the Pi's address: 192.168.77.1 with the ready-made SD card (B), or
the Pi's address on your network with apt (A). The Connectivity section of
the PushNav page shows the exact addresses to use.
- SkySafari or Stellarium Mobile: add a telescope of type Meade LX200
Classic over Wi-Fi/TCP at the Pi's address, port
4030. See SkySafari & Other Apps. - Stellarium (desktop): use the Stellarium telescope plugin at the Pi's
address, port
10001. See Stellarium Setup.
Status light
With no screen attached, the Pi's own LEDs show what PushNav is doing. Red means it needs your attention; green means it's working.
| What you see | What it means | What to do |
|---|---|---|
| Red, slow blink | No camera found, or PushNav is trying to reconnect to it | Check the camera cable |
| Red, steady | The camera was unplugged while in use, and reconnecting failed | Plug the camera back in: PushNav finds it within about 10 seconds |
| Green, slow blink | Ready, needs a sync | Open the page and run the sync wizard |
| Green, short flash every 3 seconds | Tracking, all good | Nothing: enjoy observing |
| Green, fast blink | Lost the stars | Check where the scope points, or for dew on the lens |
| Three quick green blinks, once | A phone, Stellarium or SkySafari just connected, or sent a target | Nothing: PushNav got it |
The "all good" flash is deliberately brief, so it doesn't spoil your night vision. After a target or a new connection's three quick blinks, the light goes back to its pattern.
While the Pi boots, and whenever PushNav isn't running, the LEDs behave as they normally do on a Pi. When PushNav starts, they go dark for a few seconds (up to about 20 seconds on a Pi 3A+) until it's ready and the status light takes over.
On a Pi with only a green LED (such as the Pi Zero 2 W), "no camera" is a green double blink and "camera unplugged while in use" is steady green.
Good to know:
- Some Pi cases hide the LEDs. A case with a window or light pipe over them makes the status light visible; the PushNav Pi 3A+ box has a window over them in its back wall.
- While PushNav runs, the green LED no longer flickers with SD card activity. On a Pi 4, the red LED also stops warning about a weak power supply.
- To turn the status light off, set
"led": {"enabled": false}inconfig.json(see below), then runsudo systemctl restart pushnav-headless.
Debug mode
Debug mode adds a Debug panel at the bottom of the PushNav page. Its
sample star images stand in for the camera, so you can try the sync
wizard indoors or check a setup without a clear sky. The panel can also
save the current camera frame (to /var/lib/pushnav-headless/Downloads
on the Pi).
To turn it on, put a jumper across pin 39 (GND) and pin 40 (GPIO21), the last two pins of the 40-pin header, at the opposite end from pin 1:
            pin 1 end ...  37  ●  ●  38
                           39  ●  ●  40   ← jumper across these two
                               GND  GPIO21
Then restart PushNav: power-cycle the Pi, or run
sudo systemctl restart pushnav-headless. To turn debug mode off, remove
the jumper and restart again. PushNav checks the jumper only when it
starts.
- Use only pins 39 and 40. Never connect a GPIO pin to the 5 V pins.
- A HAT that uses GPIO21 (some I2S audio boards do) leaves debug mode off, because PushNav can't read the pin.
- To see what the Pi reads, run
sudo /usr/lib/pushnav-headless/python/bin/python3 -m evf.engine.debug_pin --check.
Managing the service
| Task | Command |
|---|---|
| Is it running? | systemctl status pushnav-headless |
| Watch the log | journalctl -u pushnav-headless -f |
| Stop / start / restart | sudo systemctl stop pushnav-headless (or start / restart) |
| Don't start at boot | sudo systemctl disable pushnav-headless |
| Start at boot again | sudo systemctl enable pushnav-headless |
PushNav runs as its own pushnav system user. Its files are in
/var/lib/pushnav-headless:
- Settings and calibration:
config/electronic-viewfinder/config.json - Log file:
state/electronic-viewfinder/logs/evf.log
Settings you change in the web UI are saved there automatically. If you
edit config.json by hand, restart the service afterwards.
For power users: installing a .deb yourself
These work the same with both setups. Log in to the Pi over SSH first
(ssh pi@192.168.77.1 on the hotspot of a ready-made card).
Get the .deb onto the Pi
- Over the network, from a laptop on the same network or hotspot:
scp pushnav-headless_<version>_arm64.deb pi@<pi-address>: - On the SD card, from a PC: copy it to the boot partition. On the Pi
it is then in
/boot/firmware/.
A ready-made card installs the .deb it finds only on its first boot.
A .deb you copy onto it later has to be installed with the commands
below.
Install, update or reinstall
| What | Command |
|---|---|
| Install, or update to a newer version | sudo apt install ./pushnav-headless_<version>_arm64.deb |
| Install the same version again | add --reinstall |
| Go back to an older version, or install a local build | add --allow-downgrades |
| Install a copy from the boot partition | sudo apt install /boot/firmware/pushnav-headless_<version>_arm64.deb |
| Which version is installed? | dpkg-query -W pushnav-headless |
Settings and calibration are kept, and if you disabled starting at boot, that stays disabled.
- No internet needed: the package depends only on
libjpeg62-turbo,adduserandlibc6(2.36 or newer), which Raspberry Pi OS already has. - File names: a release download is named
…0.3.0.beta7-1…where a local build is named…0.3.0~beta7-1…. Both are fine: apt reads the version from inside the file.
More settings
- Verbose logging: set
"logging": {"verbose": true}inconfig.json(see Managing the service), then restart the service. -
Debug mode without the jumper: add a systemd override.
sudo mkdir -p /etc/systemd/system/pushnav-headless.service.d
printf '[Service]\nEnvironment=PUSHNAV_DEBUG=1\n' | \
    sudo tee /etc/systemd/system/pushnav-headless.service.d/debug.conf
sudo systemctl daemon-reload && sudo systemctl restart pushnav-headless
To turn it off again,
sudo rm -r /etc/systemd/system/pushnav-headless.service.d, then the samedaemon-reloadandrestart. - Status light off: see Status light.
Ready-made card: going online
The hotspot has no internet. To update Raspberry Pi OS or download a release directly on the Pi, put it on your home Wi-Fi for a while:
sudo nmcli con add type wifi ifname wlan0 con-name home \
    ssid "<your Wi-Fi name>" wifi-sec.key-mgmt wpa-psk wifi-sec.psk "<password>"
sudo nmcli con mod hotspot connection.autoconnect no
sudo nmcli con up home    # the SSH session drops here
The Pi is then on your home network, as pushnav.local or at the address
your router shows. When you're done, switch back to the hotspot:
sudo nmcli con mod home connection.autoconnect no
sudo nmcli con mod hotspot connection.autoconnect yes
sudo nmcli con up hotspot    # the SSH session drops again
Uninstall
sudo apt remove pushnav-headless   # remove PushNav, keep settings and calibration
sudo apt purge pushnav-headless    # remove everything, including the pushnav user
Troubleshooting
Ready-made card: no PushNav-XXXX network appears. Give the first
boot a few minutes. Then check that the card has Raspberry Pi OS Lite
(64-bit, trixie), that user-data is at the top level of bootfs with
exactly that name (no .txt), and that the country code in it is right.
Ready-made card: the hotspot works but PushNav doesn't open. If the
Pi's LEDs show their normal behaviour instead of the
status light, PushNav wasn't installed, usually because
the .deb wasn't on the card. Log in with ssh pi@192.168.77.1, check
sudo grep -n "PushNav .deb" /var/log/cloud-init-output.log, and
install the .deb by hand.
The log says "Waiting for camera". No USB camera is detected. Check the
cable and run lsusb: a supported camera appears as 32e6:9251,
0c45:6366 or 1bcf:2cd1. A camera with a different ID can be added in
config.json as "camera": {"extra_camera_ids": ["1234:abcd"], ...}
(then restart the service).
USB devices stop being detected at all. On some Pis the USB controller
can fail until the next reboot. If lsusb lists nothing but hubs, check
journalctl -k | grep "HC died", then reboot.
"PushNav is already running on port 8765" when you run pushnav-headless
by hand. The service is already running. Stop it first with
sudo systemctl stop pushnav-headless.
The phone can't open the address. The phone and Pi must be on the same network. A Pi on Ethernet and a phone on Wi-Fi usually works on a home router. Guest or public Wi-Fi networks often block devices from reaching each other.
No sound. The lock / lost / target sounds play on the Pi itself, which usually has no speaker. That doesn't affect anything else.
Limitations
Not there yet:
- No single ready-to-flash image: the ready-made SD card needs two files copied onto it after flashing.
- No shutdown button in the web UI: use
sudo shutdown nowover SSH.
For developers
Run from source
sudo apt install -y gcc libjpeg-dev nodejs npm   # Node 20.19+ for the web build
# install uv: https://docs.astral.sh/uv/getting-started/installation/
git clone git@github.com:meridianfield/pushnav.git
cd pushnav
uv sync --no-group desktop     # no pywebview / PyQt6 needed headless
make -C camera/linux
(cd web && npm install && npm run build)
uv run --no-group desktop python -m evf.main --no-window
Your user needs to be in the video group to open the camera
(sudo usermod -aG video "$USER", then log out and back in). Stop the
pushnav-headless service first if it's installed, because both use the
same ports.
A run from source leaves the LEDs alone, because only the service is given access to them. To try the status light from source, hand the LEDs to your user first, then give them back when you're done:
sudo .venv/bin/python -s -m evf.engine.led_helper take --group "$(id -gn)"
# ... run PushNav as above ...
sudo .venv/bin/python -s -m evf.engine.led_helper restore
Build the package
scripts/build_headless_deb.sh            # in a Debian bookworm arm64 container (Docker)
scripts/build_headless_deb.sh --host     # directly on a Pi, for quick iteration
scripts/smoke_test_headless_deb.sh       # install + run test on bookworm and trixie
The container build is the release path. It compiles the camera server against bookworm's C library so one package runs on bookworm and trixie. On an x86 PC, Docker runs the arm64 image under QEMU, which works but is slow. CI builds the package on a native ARM runner and attaches it to each release.
The ready-made SD card's first-boot configuration is
packaging/headless/user-data; CI attaches it to each release next to the
.deb, and tests/test_headless_user_data.py checks it.
Label for a ready-made Pi
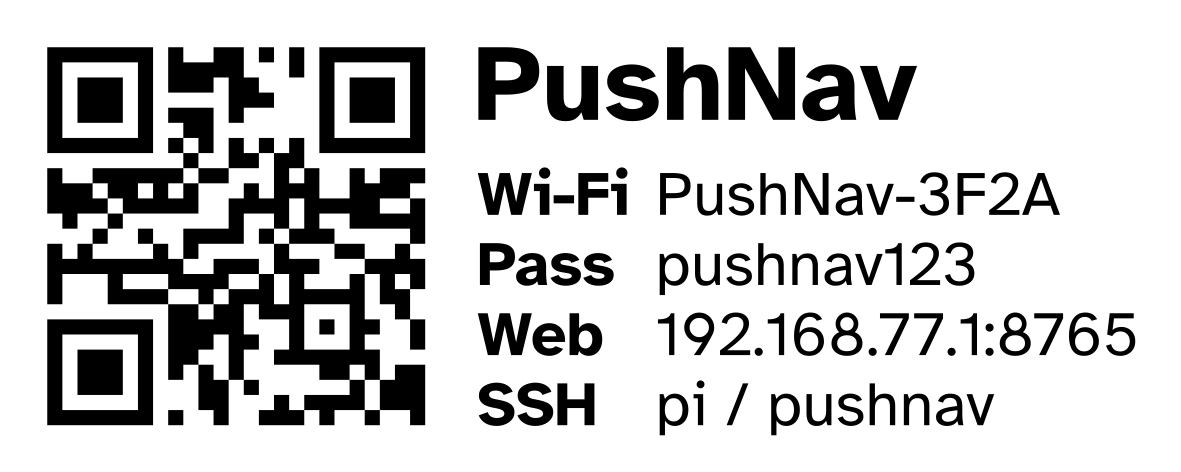
scripts/make_pi_label.py makes a 50 × 20 mm label for the box: a QR
code that opens PushNav on a phone, then the hotspot name and password,
the web address and the SSH login.
It runs on any computer (it doesn't need a Pi), from a copy of this
repository with uv
installed. uv run installs what it needs the first time.
git clone https://github.com/meridianfield/pushnav.git
cd pushnav
uv run python scripts/make_pi_label.py 3F2A
3F2A is the end of the Pi's hotspot name (PushNav-3F2A), as the
phone's Wi-Fi list shows it. The script writes pushnav-label-3F2A.svg
and pushnav-label-3F2A.png, a 300 dpi image for apps that only take
pictures (--dpi 600 for another resolution). It takes the passwords and
the address from packaging/headless/user-data. If you changed them for
your card, point it at your copy with --user-data path/to/user-data.
--help lists the other options.
The text is drawn as shapes, so the SVG looks the same in any app; print
it at 100% (actual size). The font is Atkinson Hyperlegible (in
scripts/fonts/, SIL Open Font License), which keeps look-alike
characters such as 8 and B, or 0 and D, apart.